|
Ole Banning
I'm researching on radar-camera fusion for 3D object detection in autonomous driving, supervised by Philipp Wolters. In this research, I design radar-specific serialization curves and use them to train a frustum-based model for robust 3D object detection across diverse environmental conditions. This project concludes my studies.
|
|
Projects |
|
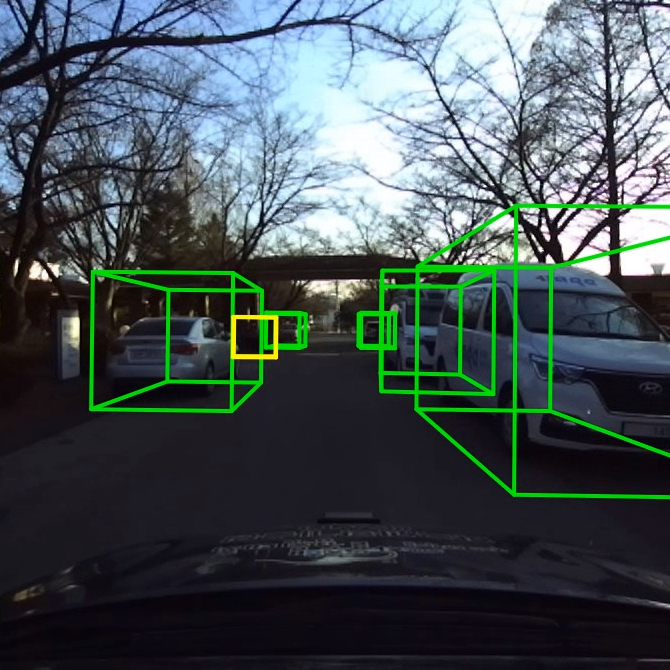
Radar-Camera Fusion for 3D Object Detection in Autonomous Driving Utilizing 4D Radar Data
Ole Banning 2026 project page / code Our method detects 3D objects from radar and camera input using radar-specific feature extraction and sparse frustum fusion to overcome diverse environmental conditions. |
|
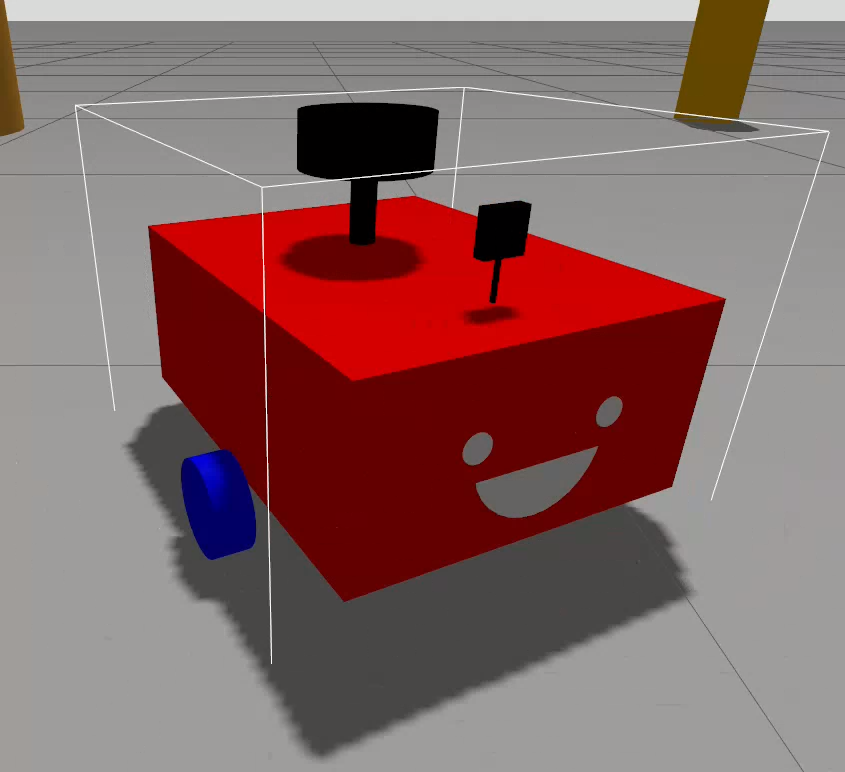
Autonmous Navigation in ROS
Ole Banning 2026 project page / code In this work I built a differential drive robot with online asynchronous SLAM and autonomous navigation with ROS2 and Gazebo. |
|
Grasp Planning
Ole Banning 2024 project page / paper In this seminar paper, we outline the challenges of task-oriented grasping, two promising approaches, FoundationGrasp and CaTGrasp, and discuss future directions of task-oriented grasping. |